 Store

 EN
 CN
 VI
 IT
 ES
 TH
 JA
 PT
 MS
 KO
 FR
 DE
 ID
Small Scale
Powerful Motion
Micro drive solutions designed for compact robotics, precision devices, and intelligent machines.
Micro drive solutions designed for compact robotics, precision devices, and intelligent machines.
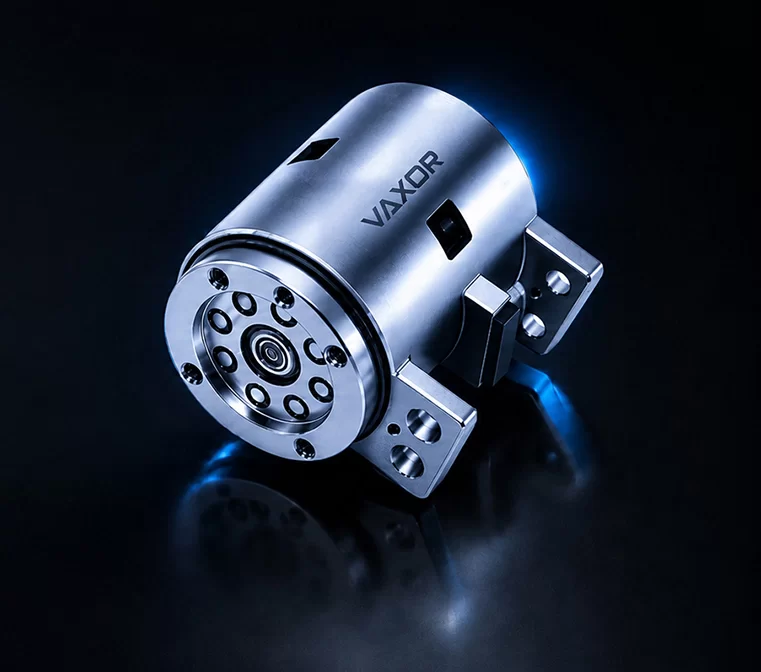
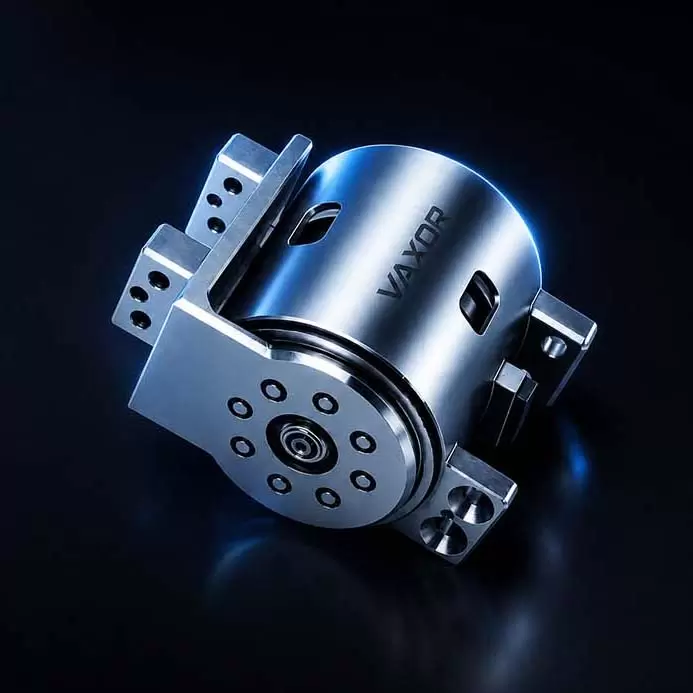
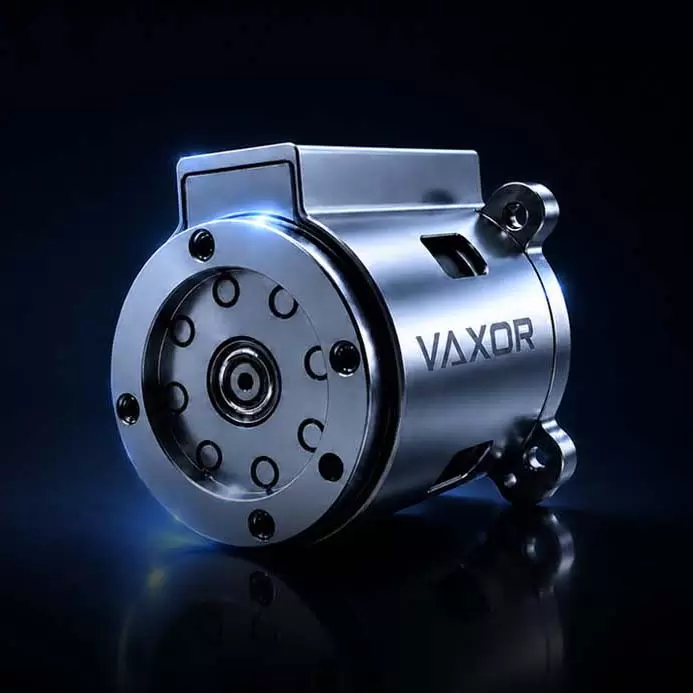
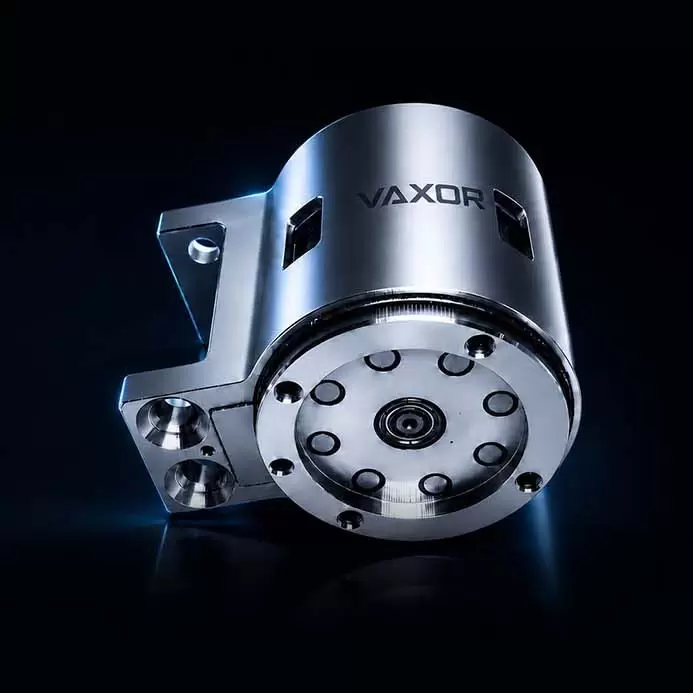
Covering Φ16mm-Φ30mm
specifications, VAXOR micro joint
actuators are engineered for compact,
high-precision motion.
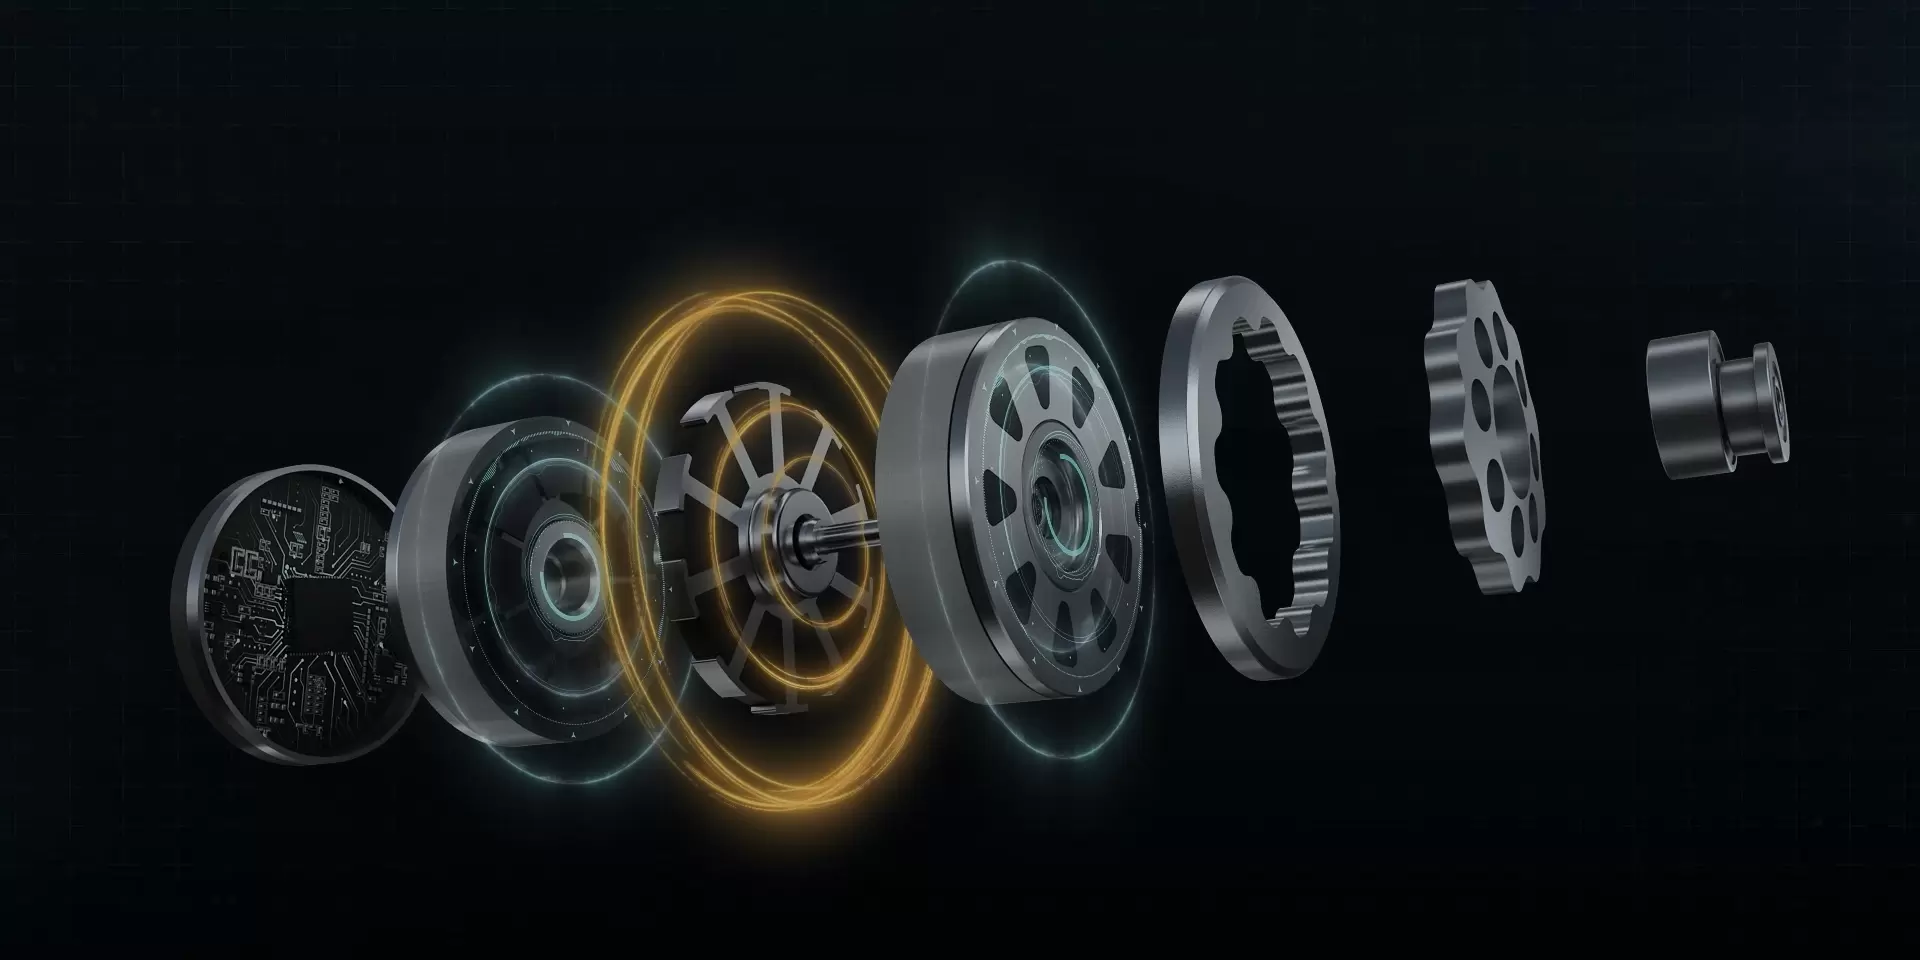
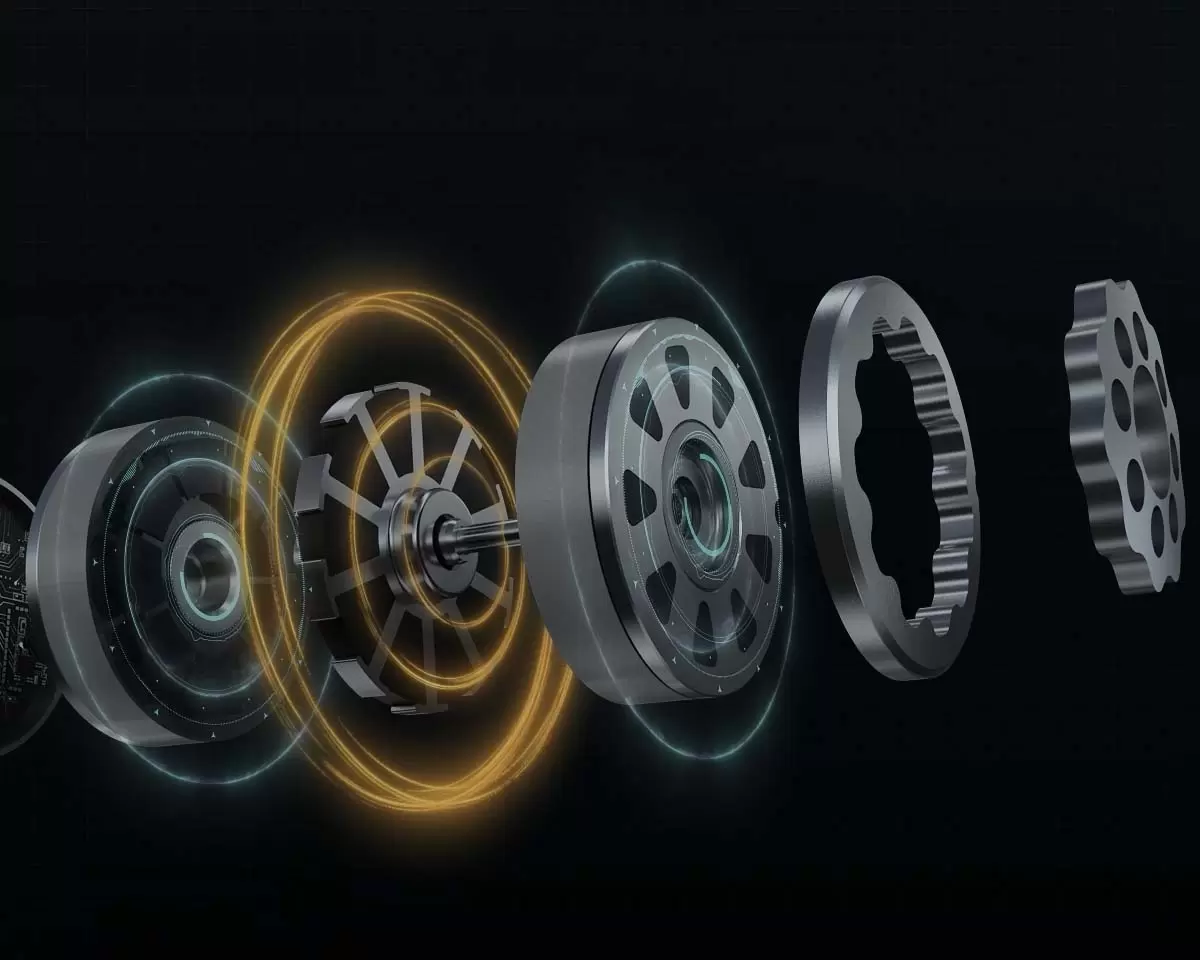
Integrated motor, reducer, and encoder design
enables high torque density, strong rigidity,
and reliable motion control.
Built for robotic joints, dexterous hands,
industrial automation, and precision devices,
they bring powerful motion into smaller spaces.
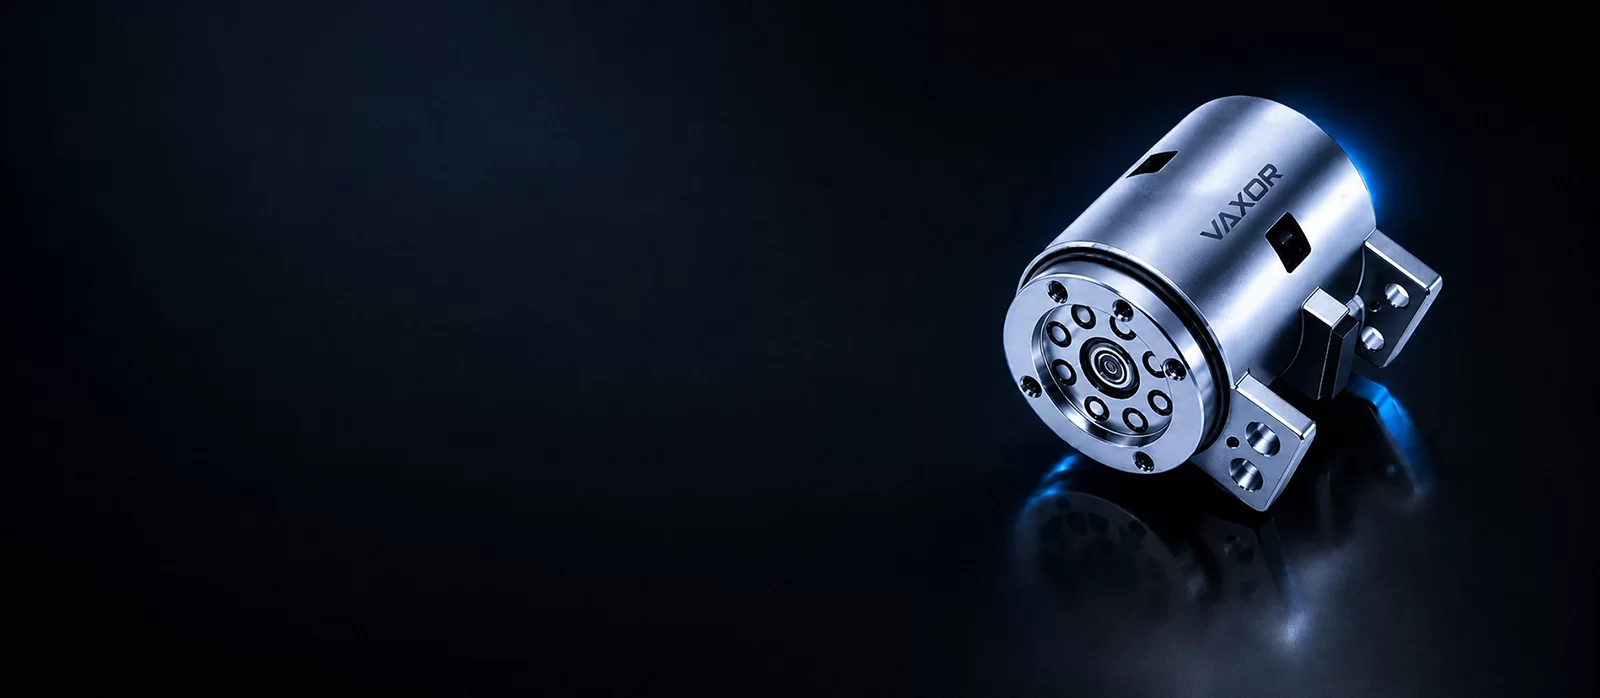
One of the few mass-produced Φ16mm joint modules in the world. Featuring high-density HDI PCB winding technology and a high-precision encoder, it achieves angular accuracy of up to 0.02°, making it ideal for dexterous hands and highly integrated robotic systems.
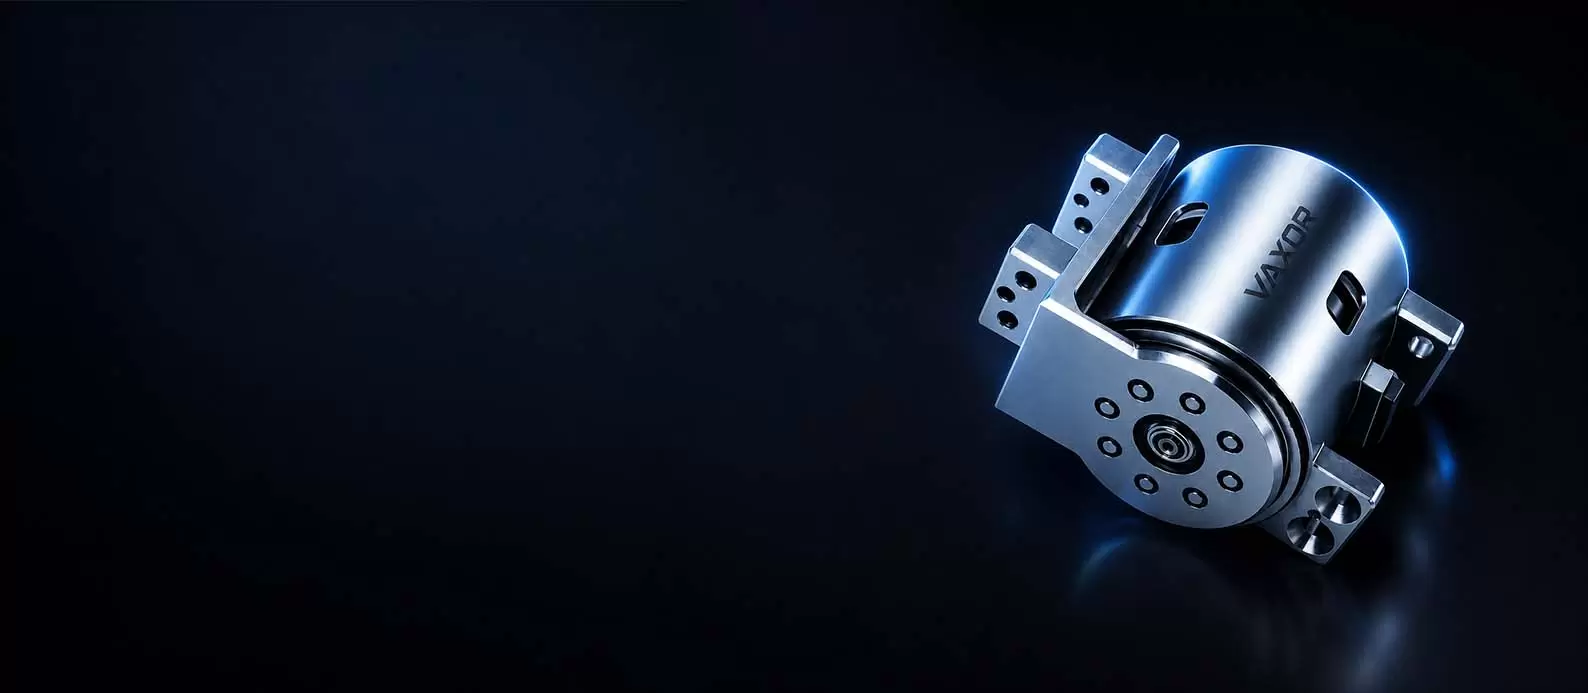
The flagship X20 measures only Φ20mm × 20mm, making it one of the world's most compact joint modules. Its innovative axial flux motor architecture delivers over 30% higher torque density than conventional designs while maintaining an ultra-compact footprint.
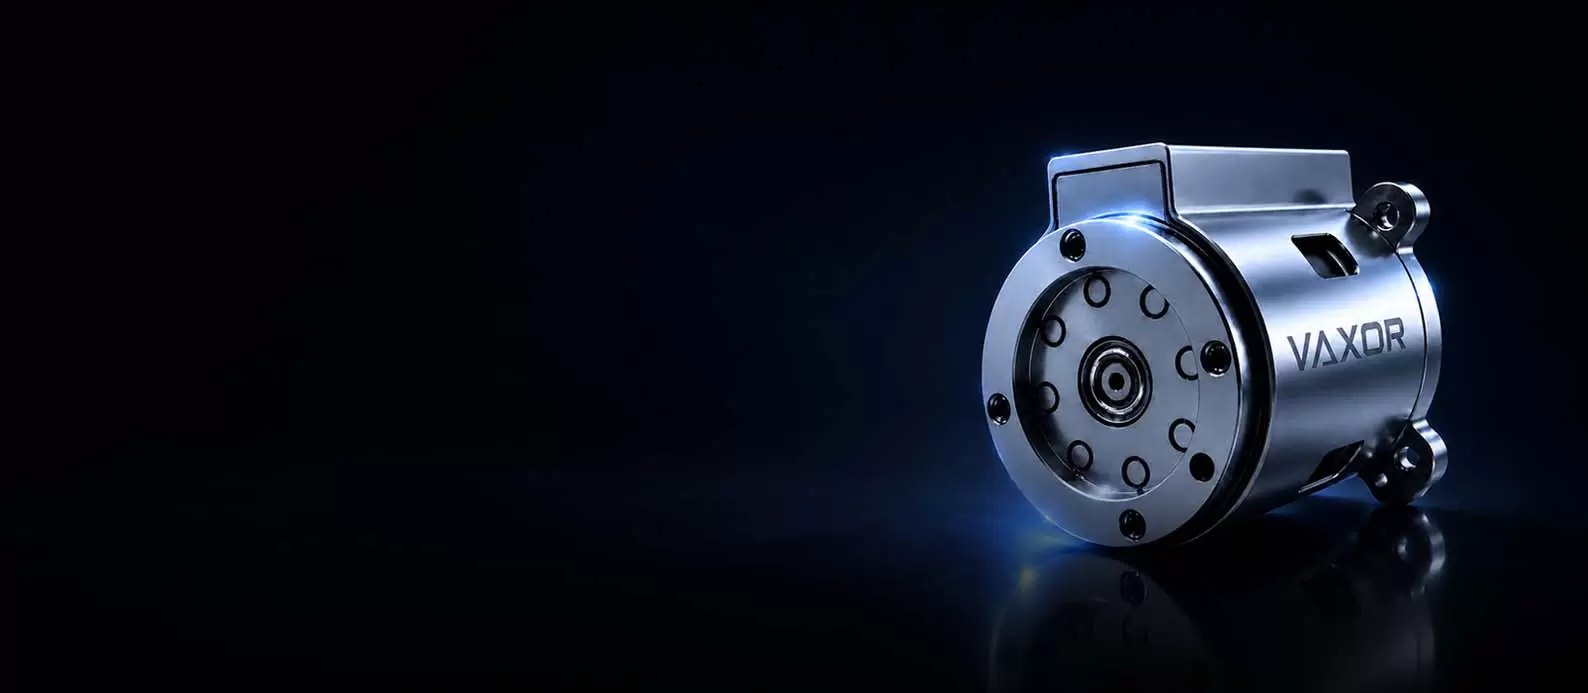
Integrating axial flux motors, miniature cycloidal reducers and non-contact encoders, the Φ25mm actuator achieves an optimal balance of precision, load capacity and cost, making it ideal for collaborative robots and biomimetic joints.
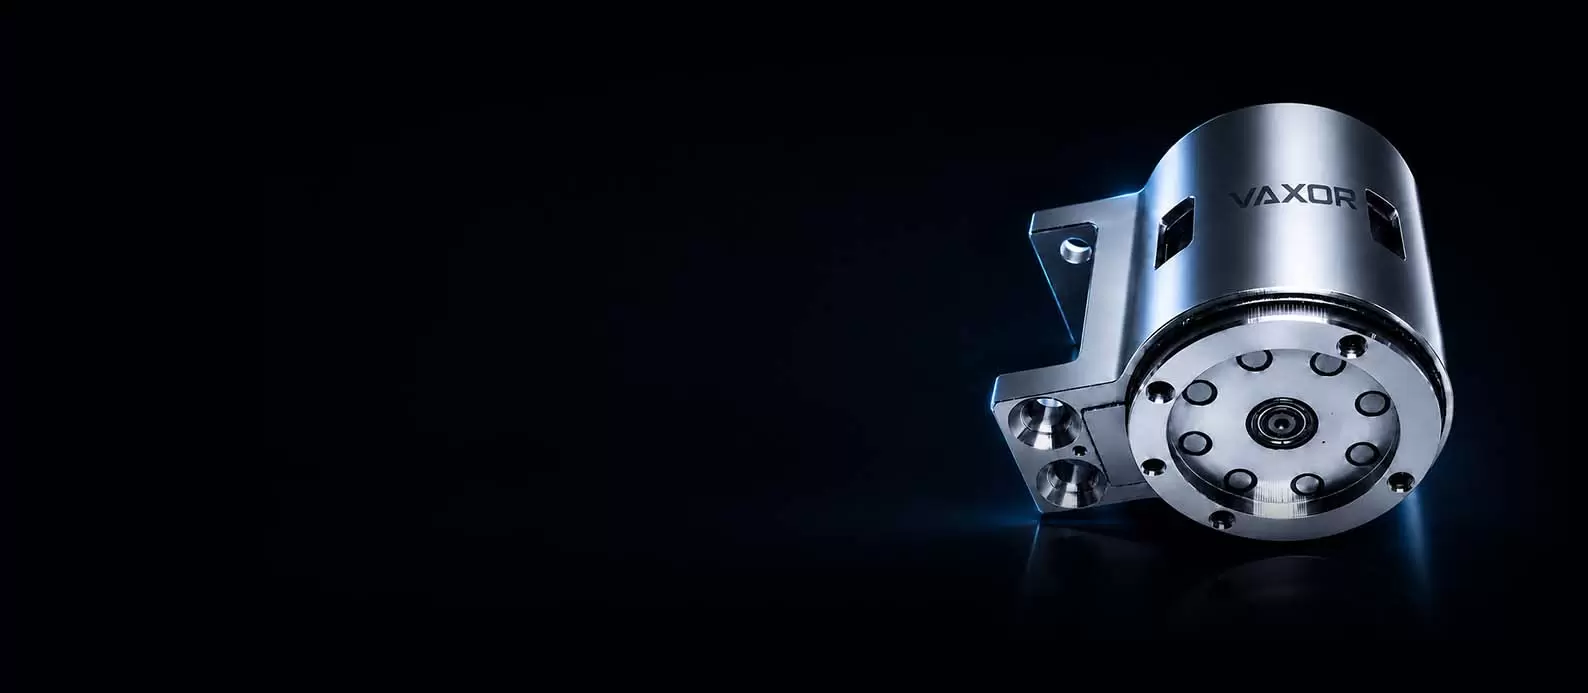
Designed for medium-to-high load applications, the Φ30mm actuator delivers Newton-meter level output and high structural rigidity, enabling stable and reliable motion control for humanoid robots, exoskeletons and robotic joints.
With a world-leading diameter of just 4mm, this motor is engineered for extreme space constraints, delivering irreplaceable drive solutions for medical devices, precision instruments and advanced miniature applications.
The Φ5mm motor achieves an exceptional balance of performance, cost and manufacturability. Combining FPCB winding technology with AI-optimized design, it delivers reliable motion solutions for UAVs, wearables and beyond.
The Φ6mm motor enhances torque output and drive stability, delivering robust performance for demanding miniature applications within a compact footprint.